



 VIP会员


In radiation treatment, patients are placed in a location prior to treatment, where the target area is mapped on the basis of the image at the time of the location, and a programme of treatment is developed to ensure that radiation is accurately targeted at the tumor. The locator line on the patient's surface and fixed devices allows the patient to be positioned as closely as possible for each treatment, but the position of the tumor may change slightly due to changes in the patient's position and respiratory activity, which affects the accuracy of the treatment. Igrt uses video equipment (e. G. X-rays, ct, mri, etc.) to obtain real-time information on changes in the tumours in patients and their surrounding normal tissues, and adjusts the radiation exposures to this information in real-time, thus improving the accuracy of treatment and reducing damage to the surrounding normal tissue. With the development of medical video technology, igrt plays an increasingly important role in the treatment of oncology。
How can the accuracy of positioning be determined
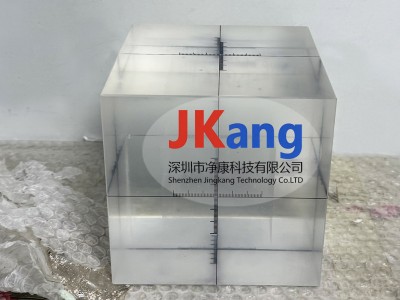
Wek-1650 igrt target position calibration model, and wek-1650 igrt target position model will be achieved1. Models consisting of solid water
2. Outer dimensions: 150 mm x 150 mm x 150 mm
3. Two-and-a-half, symmetry
4. Central embedding 2mm oarball (half balls top and bottom)
5. Cross-lined scale
6. The precise size of which cross marks are placed at the centre of each side, and the central point of the cube has been placed at a distance of 2. 00 mm, with a high-density bead ball, with steel balls placed around the map size
7. Central point coordinates p0 = (x0, y0, z0)
8. 4 points (red dots) on the boundary of the target area for a sphere of head model targets = 50 mm
P1 = (x0+14. 43; y0+14. 43; z0-14. 43)
P2 = (x0+14. 43; y0-14. 43; z0-14. 43)
P3 = (x0-14. 43; y0+14. 43; z0+14. 43)
P4=(x0+14. 43; y0+14. 43; z0+14. 43)
Embedded position is actually a dot at 14. 43mm ball circle!
P2 = (x0+14. 43; y0-14. 43; z0-14. 43)
P3 = (x0-14. 43; y0+14. 43; z0+14. 43)
P4=(x0+14. 43; y0+14. 43; z0+14. 43)
Embedded position is actually a dot at 14. 43mm ball circle!
9. For body model target area = 100 mm sphere, 4 points on target area boundary (yellow point)
P5 = (x0-28. 87; y0-28. 87; z0-28. 87)
P6 = (x0+28. 87; y0+28. 87; z0-28. 87)
P7 = (x0+28. 87; y0-28. 87; z0+28. 87)
P8 = (x0-28. 87; y0+28. 87; z0+28. 87)
The nested position is actually a dot in the circle of 28 87mm!
P6 = (x0+28. 87; y0+28. 87; z0-28. 87)
P7 = (x0+28. 87; y0-28. 87; z0+28. 87)
P8 = (x0-28. 87; y0+28. 87; z0+28. 87)
The nested position is actually a dot in the circle of 28 87mm!