


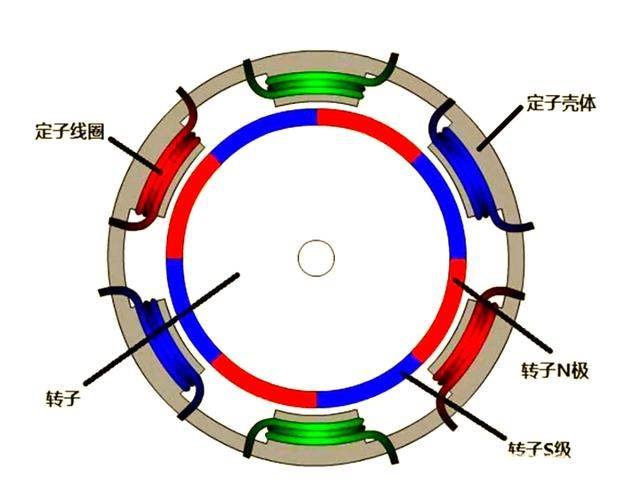
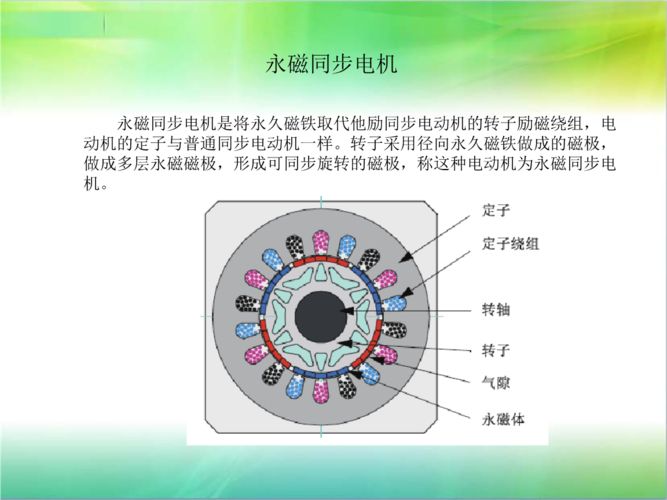
1.-. Z. The emso is based on the principle of exchange and operation of 211 emso and consists of a wide variety of esos, which can be divided into sine wing wing wing wing wing (pmsm) and tread wing wing wing wing wing wing (bldc) [261]. The chords are composed of three contour groups and iron cores, which are often connected to the y type using short-range distribution around groups; the gas field is designed as a sine wave to generate a sine-reverse dynamic; and the rotors are replaced by a permagnetic body, which is divided into three categories according to the location of the integrator on the rotor: cam, embedding and internal. The electrons used in this paper are condensed swirl-long magnetic synchronous electric machines, constructed as shown in figure 211l, which are typically multiphased in fixed circuits consisting of permanent magnets with a fixed logarithmic bar, with two pairs of electron rotor magnetic poles in the system
2. Electric velocity n=60fp, f for current frequency and p for extreme logarithm. Figure 2 1l scale sine permagnetic synchronous power structure currently has three main controls, one of which is his control (also known as frequency opening control) and the other self-control (also known as frequency closed loop control)27]. He regulates the rotation of rotors mainly through independent control of the n#l-power frequency without information on the location of the rotors, often using the open-ring control programme of the constant frequency ratio. A self-controlled constant-magnetic-synchronous power machine also regulates the rotation of rotors by changing the frequency of the external power, which, unlike his control, is associated with the location information of the rotors, the higher the rotor turns, the higher the fixed entanglement frequency, and the rate of rotors is adjusted by changing the size of the voltage (or current) extra-voltage frequency. Because there's no such thing as a self-controlled synchronous machine
With the problems of 3-step and oscillation, and the absence of electric brushes and transducers for the irreversible synchronous electrons, the reduction in the size and quality of the rotors, the improvement of the system's speed of response and velocity* and the performance of the direct current electric motors, this paper uses the self-controlled exchange ional magnetic synchronizer. When three relative power sources are added to three relative rounding groups, a synchronous rotation of the stationary magnetic field is naturally generated, and the synchronous electrons are revolving at a strictly synchronized rate with the frequency of the external power source and not related to the load size. The system for the exchange of the working principles of the emso is controlled by the self-controlled direct-to-voltage type of electric power, consisting of a whole-stream bridge, a three-way reverse circuit, a control circuit, a three-way exchange pv and a location sensor, the structure of which is shown in figure 22. In figure 22, 50hz's municipal electricity flow is complete, powered by three reversers to three circuits of the electric power, three relative to the current synthesis of the spinning magnetic field and rotor forever
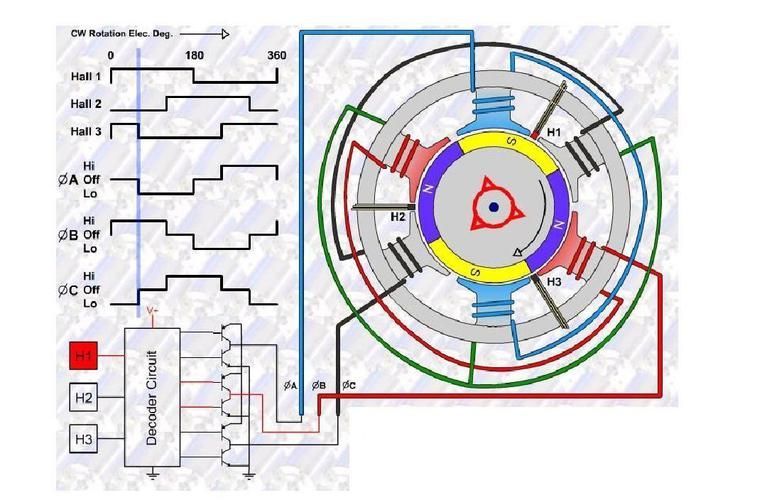
4- the magnetic field interaction from a long-duration magnetic steel produces rectangular rectangulars, drags the rotor synchronous rotation, reads the rotor magnet position in real time through the location sensor, converts it into a telecommunications signal to control the retrovert power device switch, regulates the current frequency and phase, and maintains a stable position relationship between the quartz and the rotor magnetic position, in order to produce a constant rectangular rectangular, and the current size in the fixed circuit is determined by the load. When the frequency and phase of the three-phase currents in the fixed circuit group changes with the position of the rotor, the three-phase currents are synthesized into a rotating magnetic field synchronized with the rotor. The three-phase currents are replaced by mechanical converters by switch changes in the reverse circuits made up of electrical electrons. Figure 22 shows the principle of self-controlled electromechanical swirling and magnetic synchronous machines, which are self-controlled electric machines, except for the electro-motive inverting and current wave shapes, which are both swirling and similar, and which can have the same rectangular properties as the direct electrons and achieve a constant rectangular velocity feature. Place
5. The servo system is designed to perform position-based service functions through a chord-long magnetic synchronous machine. The servation system of the 213 rotation encoder, consisting of a self-controlled sine wave pmsm, requires real-time detection of the location and speed of the electric rotor, which captures the relevant information through the rotation encoder. Depending on the method of work of the encoder, it can be divided into magnetic encoders and optical encoders, and according to the output signals of the encoder, into an incremental and an absolute (absolute) encoders. An absolute encoder can directly measure the absolute position of the rotor, providing a unique code numerical value for the location of the rotor. There are many radial encoders on the absolute-type encoder (rotation) coding board, organized in two lines, four lines, eight lines, 16 lines, at each location of the encoder, to obtain a set of zeros from 2 by reading the pass and darkness of each encoder
The only binary code for the 6-to-2 n-1 side is called the n-bit absolute encoder. The encoder is determined by the mechanical location of the pv disk and is not affected by power outages or interference. The incremental encoder can only return the relative position of the rotor at each time. The incremental type can only measure the angular shift (indirectly the angular velocity) increment, which was the base point at the previous point. The photoelectric incremental encoder (rotational) is a central axle photocoded with a circular, dark engraving, which is read by a photo-launching and receiver, and receives a combination of four sine wave signals into a, b, c, d with a 90-degree phase difference (compared to a weekly wave of 360 degrees) and increases the stability of the c, d signals by supersing them to a, b, and a z-pulse per turnout to represent a zero-point reference position. Because of the difference of 90 degrees between the a and b pulsing signals, the encoders can be distinguished by comparing the a to the b to the b to the a to the b to the a to the b to the b
7. Inverted and inverted, the coder's zero reference level is available through a zero pulse. Encoders are referred to as the resolution of how much pass or dark cipher is provided at 360 degrees per rotation, or as the resolution of the resolution, or as the direct number of lines, generally at 510,000 lines per rotation. Optical incremental encoders and magnetic incremental encoders, output signal messages are essentially the same. The main advantage of optical encoders is that they are sensitive to humid gases and pollution, but have poor reliability, while magnetic encoders are not susceptible to dust and exposure, while they are simple and compact, can operate at high speed, respond quickly (up to 500,700 khz), are smaller in size than optical encoders, and have a lower price (28). The system uses a rotating incremental magnetic encoder, which is highly adaptable to the environment and reacts quickly and is very suitable for detecting the speed and location of electric motors in high-speed rotation movements. Twenty-two to communicate the mathematical chords of the constant magnetic synchronous electrons
The three-step machine of electro-magnetic magnetism is the same, and the counter-electricity is also a swirl wave, and its mathematical model is the same as the three-step machine of electromagnetic. An instant electrical current in a three-contangible group, as shown in figure 23. The three-phased group flow balance is i,ib,ic, respectively, 120 in space. The instant current expression is as follows: (21) im is the maximum current value. The three-circular circuits of the three-line circuits of the three-wire circuits, symmetrically symmetrically symmetrically symmetrical, are shown in figure 24 in figure 23, phase-two-2 of the stationary three-phase coordinates for the establishment of the electrons. It is the tirconium tirconium (tirconium tirconium); o, tirconium tirconium (tirconium tirconium tirconium) (pb, tirconium tirconium tirconium (tirconium tirconium tirconium); r is tirconium tirconium (tirconium tirconium tirconium) (tirconium tirconary) (tirconium tirconium tirconary) (tirconium tirconium tirconary) (tirconium tirconary) (tr). Magnetic chain equations are [29]: 2-3 23 begging, 厶, =, =, =, =. ♪ k ♪ beg, k ♪
9 and k, respectively, are the sense of interaction between the two conjunctive groups; each is the magnetic chain of the permagnetic rotor, the second = rot+ island is the angle of the rotor with the three stationary coordinates a-axis, and the zirconium is the initial position of the rotor. In order to simplify the analysis, the following assumptions are made: 1) the magnetic circuits of the iron-magnetic part of the electric machine are linear, not saturated, remaining magnetic, magnetic and vortex effects; 2) the fixed triform symmetrical group is symmetrical and is a centralized rounding group; 3) the effect of the resonance of the power hubs on the magnetic field is ignored; this allows the sense of self and cross-fertilization of the contour groups to be unrelated to the positional angle of the rotor, and the three contangular circuits of the permanent magnetic synchronous electron are symmetrical distribution, as opposed to asymmetric distribution, as opposed to star-shaped, =t= triform, k=z-aac= begging=k=k=m, iii and m are constant, and therefore the magnetic + = 0, so that china is organized as a synchronous velocity. Based on the three-tangular motion equation of 25, each of the contangible bands is ea, e, e
10. The same three relative currents also vary from time to time, so the system's output rectangular changes and the convergence of parameters make it difficult to achieve complex rectangular controls throughout the system. The vector control theory of the exchange power suggests that it is the first qualitative leap in the power control theory, making the control of the exchange power as simple as that of the straight current power and allowing for better dynamic performance. The fundamental idea of vector control is that, on the directional coordinates of the rotor magnetic field, the current vector is broken into a magnetic current fraction that produces magnetic flux and a rectangular current fraction that produces magnetic flux, and that the two fractions are vertically and independently of each other, so that they can be reconciled separately and the decomposition of the control of the exchange engine is achieved [30i, also known as the d-q coordinate system, the d-axis are fixed on the transmagnetic axis and the q axis is rotated 90 in the direction of the d-axis. The electron angle, figure 25 is the rotational coordinate system with a polar logarithm of 2. Besides, the three-phase power flow in the zong group will pass through one
11. Space vector currents are expressed in the following expression: if the active value of the two-to-seven medium o, the three-phase currents is i and the angular frequency is coloured, expression 27 can be simplified: 2-8 i can be considered as a vector rotated at an angle speed, as shown in figure 25. Figure 25 rotation coordinate system first, the three-phase stationary coordinate system in which the three-phase exchange currents are located is to be converted to two-stationary coordinates one. On the fixed dots, a one-axis coordinate system is established, the axle is re-coordinated with a, and the arc is rotated 90-hourwise. For axes, the expression converted to two stationary coordinate systems is as follows: it is then converted from the static one-axis coordinates to the d-q coordinates system, as shown in figure 26, with the conversion expression:
The mid-points of 12, 2-10 are the angles of two coordinates. The conversion relationship between the d-q coordinates and the three-phase static coordinate systems can be derived from formula 210 as follows: the fixed magnetic chain equation of the communication permanent magnetic server is: a magnetic chain, which is expected to be generated by the rotor permagnetic system, in forms 2-13; acoustics, radiums, electrodynamics, direct axial senses; and acoustics, which are converted into accelerator: the rectangular equation of the electron, following its conversion by coordinates, can be expressed as follows: 2-15 for the magnetic chain equation: 5 in the contour reference coordinates for a polar logarithm of 2-16, assuming the d-axis are a void q-axis, within which the fixed current space vector f is expressed: 2-17f and the q-axis are targeted, and 2-18 for the contangular equation: 2-19 gills are essentially inter-arranged between the axis of the rotor magnetic field and the axis of the contour magnetic field. In the above formula, the first of the brackets is the electromagnetic rectangles resulting from the interaction of these two magnetic fields, as shown in figure 27, curve i; the second of the brackets is referred to as magnetic resistance short (curve)









